01 About
Hyunseo Jang
M.S. Student, Korea University
Research Intern, AVE Lab, KAIST
I am an M.S. student in Mobility Science and Engineering at Korea University and a research intern at AVE Lab, KAIST. I will join KAIST's Cho Chun Shik Graduate School of Mobility as a Ph.D. student in March 2027.
My research investigates camera-LiDAR scene representations and vision-language models for mobile robots. In ROMO-S, I study whether generated surround views support spatial understanding beyond a forward-facing camera. My earlier work includes autonomous mobile-robot integration, reinforcement learning, and simulation-based design optimization.
Selected robotics work
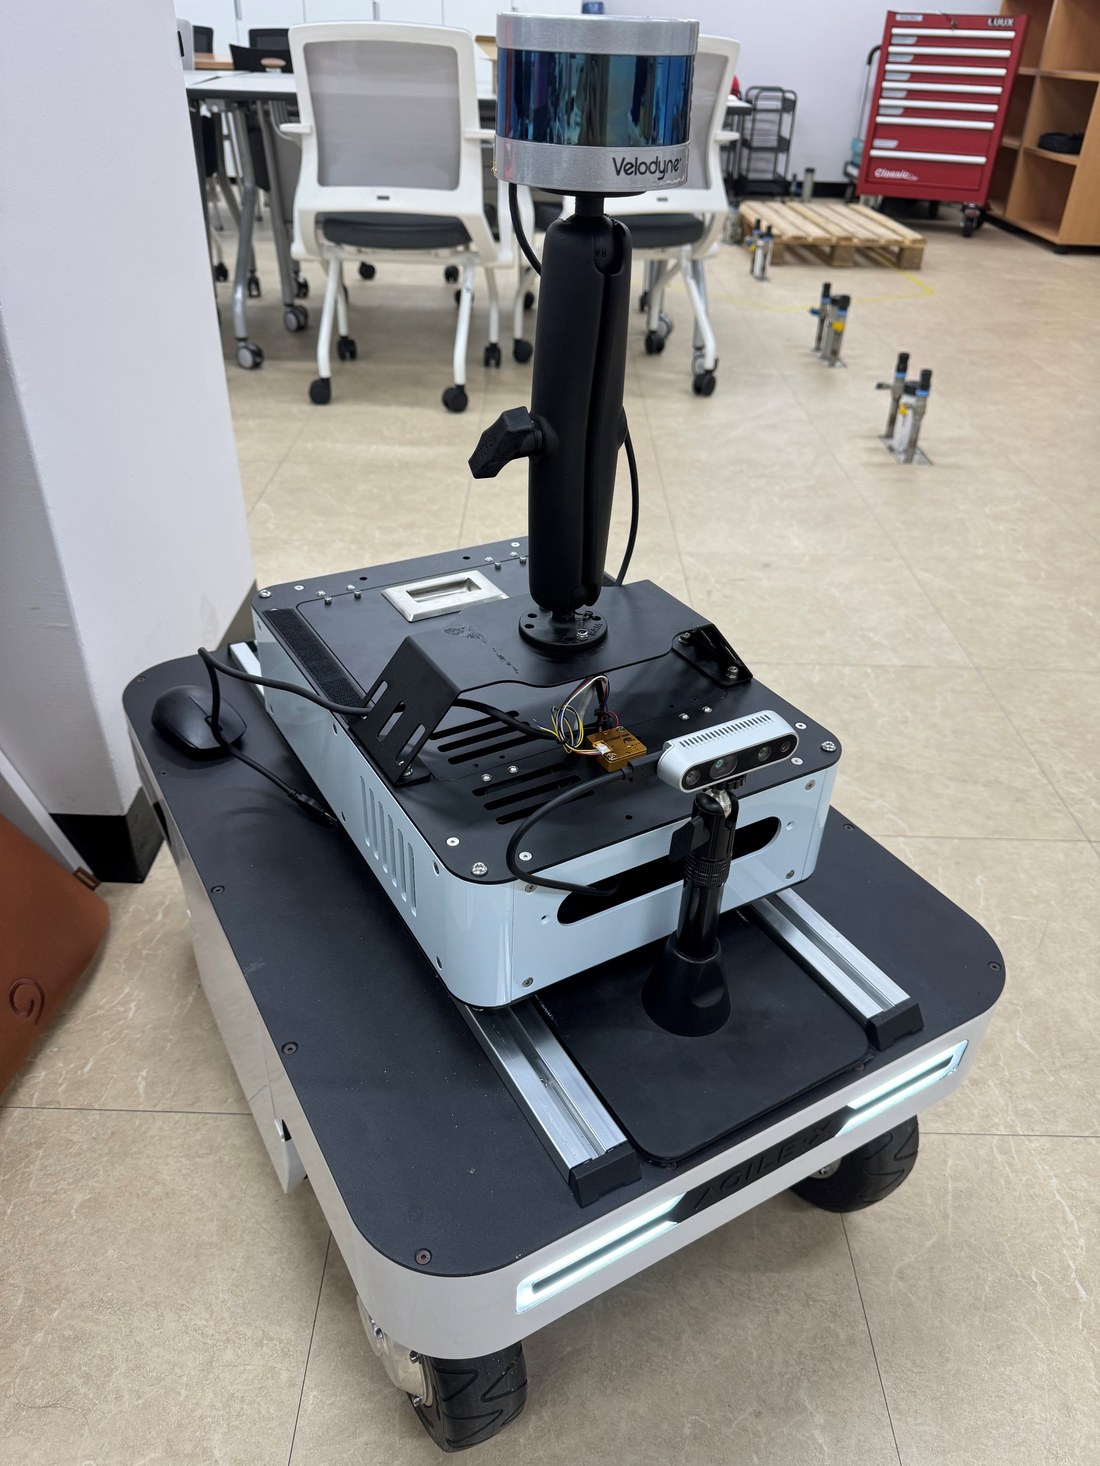 Campus AMR integration
 Inventory-inspection robot
 KALO launch assistance
News
02 Research output
Publications
Peer-reviewed journal articles, conference papers, and selected presentations.
Publication and citation record on Google Scholar
2026
2025
selected conference presentations
A Study on TDP Derivation for Functional Test Evaluation of Autonomous Work and Driving of Road-Sweeping Vehicles
Daekug Lee; Beomjin Park; Jiseung Ha; ; Seungmin Kim; Youngeun Song; Chung Ho Cho.
TDP derivation for autonomous road-sweeping vehicle function testing.
Human Trajectory Prediction Algorithm
SeungMin Kim; ; YoungEun Song.
LiDAR detection, Kalman-filter tracking, and human-robot avoidance.
A Study on the Optimal Loading Algorithm of the Local Logistics Center Based on Reinforcement Learning systems
Kim Seung Min; Ha Yeong Ho; ; Song Young Eun.
DQN-based loading policy for fulfillment and last-mile logistics.
Research on fail-safety of self-driving cleaning vehicles
Yeong-Ho Ha; Seung-Min Kim; ; Young-Eun Song.
Fail-safety considerations for autonomous road-sweeping operation.
A Study on PointCloud-based Object Detection Method for Safe Autonomous Driving of Robots in Narrow Indoor Environments
; Yeong Ho Ha; Seung Min Kim; Dae Kug Lee; Young Eun Song.
Point-cloud object detection for safe autonomous robot navigation in confined indoor environments.
A Study on the Lightweighting of LiDAR Recognition Module for Durability and Power Efficiency in Embedded Systems
; Yeong Ho Ha; Seung Min Kim; Dae Kug Lee; Young Eun Song.
LiDAR RPM, reliability, durability, and power-efficiency trade-off analysis.
A Comparative Study on the Performance of Deep-Learning-Based Object Detection Algorithms Using Aerial Images
Im Yeong Rim; Lee Dae Kug; ; Lee Dong Hun; Jeong Ki Hyeok.
YOLO-based object-detection comparison using UAV aerial-image data.
Optimal Logistics Distribution Algorithm for Autonomous Delivery for Local Logistics Hub System
Yeong-Ho Ha; Seong-Min Kim; ; Young-Eun Song.
Local logistics hub routing and distribution algorithm for autonomous delivery operation.
03 Research in practice
Projects
Multimodal perception, robot learning, and autonomous-system integration.



04 Background and experience
CV
Education, research experience, skills, and activities.
education
KAIST, Cho Chun Shik Graduate School of Mobility
Incoming Ph.D. Student, AVE Lab
Admitted Sep. 2026; starting Mar. 2027
Korea University, Department of Mobility Science and Engineering
M.S. Student, Field Robot Lab
Advisor: Prof. Youngeun Song
Expected Feb. 2027
Korea University, Department of Mobility Science and Engineering
B.S., Department of Mobility Science and Engineering
Feb. 2025, graduated with honors
current research appointment
Research Intern, AVE Lab, KAIST
Cho Chun Shik Graduate School of Mobility
Current appointment before starting the Ph.D. program in Mar. 2027
research profile
My current work investigates camera-LiDAR scene understanding and vision-language models for mobile robots. In ROMO-S, I study whether generated surround views provide useful spatial information beyond a forward-facing camera, with comparisons against bird’s-eye-view representations. My earlier work includes ROS/Autoware-based autonomous mobile-robot systems and Isaac Lab/RSL-RL environments for wheeled-legged and mobile-manipulation tasks.
- Multimodal perception with camera-LiDAR fusion, surround-view generation, and vision-language spatial understanding
- Autonomous driving with environment understanding, detection/tracking, and perception-to-planning integration
- Robot learning and simulation with Isaac Lab, RSL-RL, PPO, MDP formulation, reward shaping, curriculum design, and policy evaluation
- Field-system integration with ROS2/Autoware, CAN, LiDAR mapping, and autonomous navigation
- Stability-aware evaluation for mobile manipulation, chassis leveling, and rough-terrain driving
selected research projects
- ROMO-S: Multimodal Spatial Understanding: ongoing study of generated surround views and bird’s-eye-view representations under matched front-camera and LiDAR inputs.
- ROMO-B: Robot Navigation and Integration: public ROS 2 platform workspace for LiDAR mapping/localization, Nav2/Autoware navigation, and operator tools.
- KALO: Kangaroo-LocoManipulation: arm-motion-assisted launch control for improving acceleration and stability in a mobile manipulator.
- Lift-Equipped Mobile Manipulator: shelf-transfer mobile-manipulation task with Isaac Lab PPO setup and success/failure analysis.
- Rough-Terrain Wheeled-Legged AMR: reinforcement-learning setup for velocity tracking and chassis leveling.
- Inventory-Inspection Robot Adaptive Suspension: suspension-stabilization workflow for full-lift driving of a 10 m-class inventory-inspection robot.
- CEBO-Based Stair-Climbing Wheel Design: CoppeliaSim evaluation-loop automation and optimization for T-pedal wheel design.
- On-Campus Autonomous Mobile Robot Systems: ROS/Autoware AMR integration, LiDAR mapping, detection/tracking, waypoint driving, and campus validation.
- LiDAR-Based Campus Autonomous Driving: RTK-surveyed campus HD map, Autoware waypoint driving, and LiDAR pedestrian-detection tests.
technical skills
Robot Learning / Simulation: Isaac Lab, Isaac Sim, RSL-RL, PyTorch, PPO, MDP formulation, reward shaping, curriculum design, policy evaluation
Robot Software / Integration: ROS2, ROS, Autoware, Python, C++, Linux, CAN, Git
Perception / Navigation: camera-LiDAR fusion, vision-language models, bird’s-eye-view representations, LiDAR mapping, object detection/tracking, DBSCAN, Kalman filtering, ROS/Autoware perception integration
Design / Optimization: Bayesian optimization, CoppeliaSim, CAD, Ansys, hardware feasibility testing
honors
- 2025 National Research Foundation of Korea Master’s Student Research Grant, Individual Research Project
- 2024 Outstanding Prize, Future Mobility Research Idea Contest, Team Lead
- 2023 Grand Prize, Korea University Project Semester, Individual
- 2023 Grand Prize, DSC Regional Innovation Platform Future Mobility Startup Hackathon, Team Lead
- 2023 Outstanding Prize (2nd Place), Future Mobility and Sejong Regional Innovation Idea Contest, Team Lead
- 2023 Halla University President’s Award, HL Mando & HL Klemove Autonomous Mobility Competition, Team Lead
- 2022 Gold Prize, International Collegiate Autonomous Driving Competition, VLF Racer Division, Team Lead
- 2019 Bronze Prize, 26th Samsung Humantech Paper Award, High School Division
teaching and mentoring
- Teaching assistant since Sep. 2023 for 9 major/PBL courses, including Robot Design and Driving PBL, Mobile Robot Operating System, and Autonomous Driving Fundamental Technology PBL.
- Organized ROS-based small-vehicle, simulator, LiDAR, and vision practice sessions for junior students.
leadership and international activities
- 2022.09 - 2022.12 Led KUMob, an on-campus autonomous-driving society of about 30 members; organized ROS-based small autonomous-vehicle projects, simulator setup, LiDAR/vision practice, and mentoring workflows.
- 2021.03 - 2025.02 Held department student leadership roles, including vice president, president, and emergency committee leadership.
- 2024.01 - 2024.02 Selected as an outstanding student representative for a UNLV overseas training program; participated in a UNLV autonomous-vehicle project, robotics/vision sessions, an Intel Graphics automotive Q&A, and CES 2024.
- 2024.12 - 2025.01 Selected again for a UNLV overseas training program; completed AI + IoT, communication, and Linux-based automotive electronic-system practice, and attended CES 2025.
additional research and feasibility work
- Autonomous Road-Sweeping Vehicle TDP: ODD, fail-safety/SOTIF, validation-scenario, and TDP documentation.
- Aircraft Towing and GPAU Feasibility: autonomous/remote towing architecture, LiDAR collision-prevention concept, and Isaac Sim feasibility review.
- Residential Delivery-Robot Testbed: residential delivery-robot service scenarios and operation-check notes.