KALO: Kangaroo-LocoManipulation
Arm-motion-assisted launch control for improving acceleration and stability in a mobile manipulator.
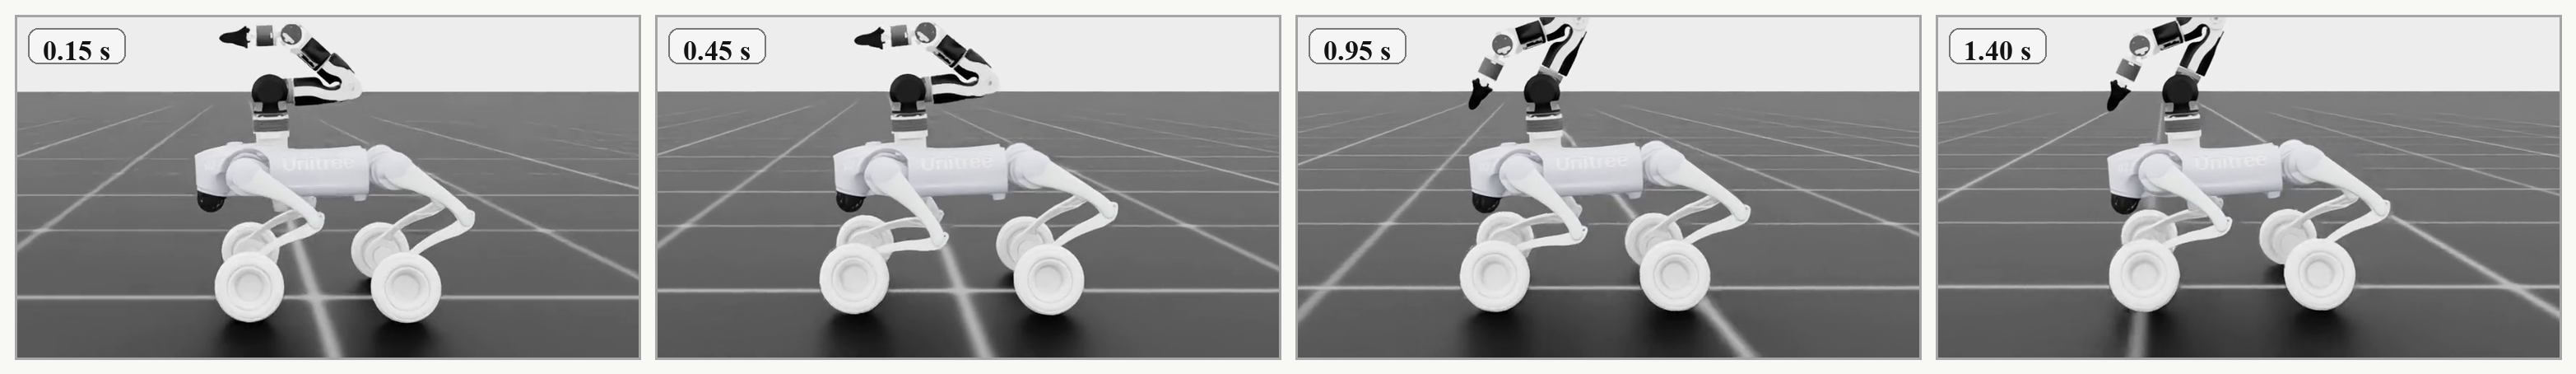
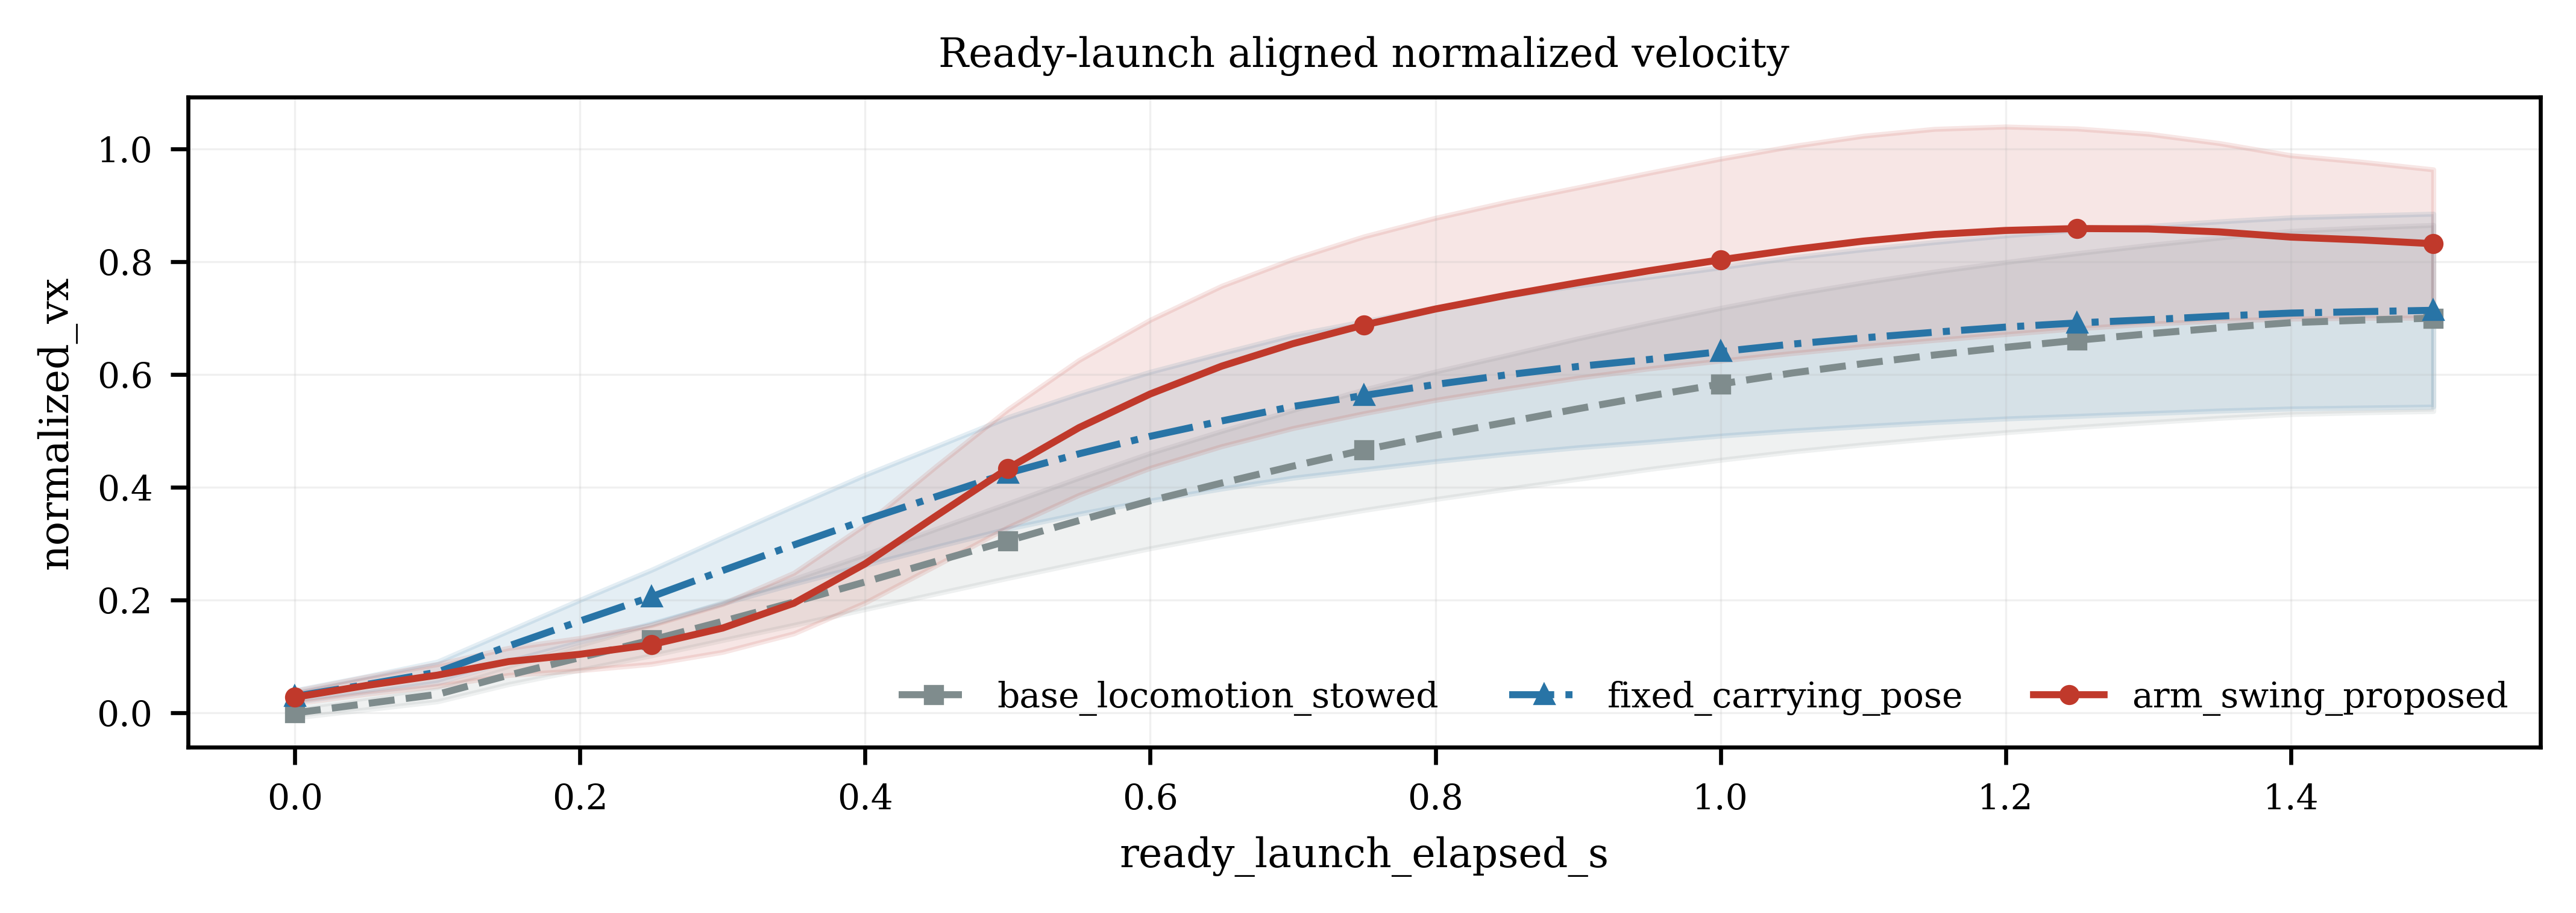
I studied arm-motion-assisted launch control for a wheeled-legged mobile manipulator. The project evaluated whether manipulator-induced inertial effects can improve initial acceleration under controlled Isaac Lab/RSL-RL simulation settings.
- Role: launch-assist concept, mobile-manipulator setup, evaluation metrics, Isaac Lab/RSL-RL experiments
- Tools: Isaac Lab, RSL-RL, PyTorch, PPO
- Result: normalized forward-velocity AUC(0-1.5 s) increased by 15.1% over Fixed (0.726 -> 0.835); t90 decreased from 1.703 s to 1.067 s; 90%-target-speed trials within 1.5 s increased from 29/128 to 69/128.
- Paper: KALO: Kangaroo-LocoManipulation for Early Launch Acceleration in a Wheel-Legged Robot. IEEE/ASME AIM 2026, pp. 1-6. DOI / IEEE Xplore
- Related code: leg-loco-isaac-lab contains the public Go2W-OpenArm experimental workspace and training/evaluation utilities. The complete paper-reproduction package is not publicly released.